
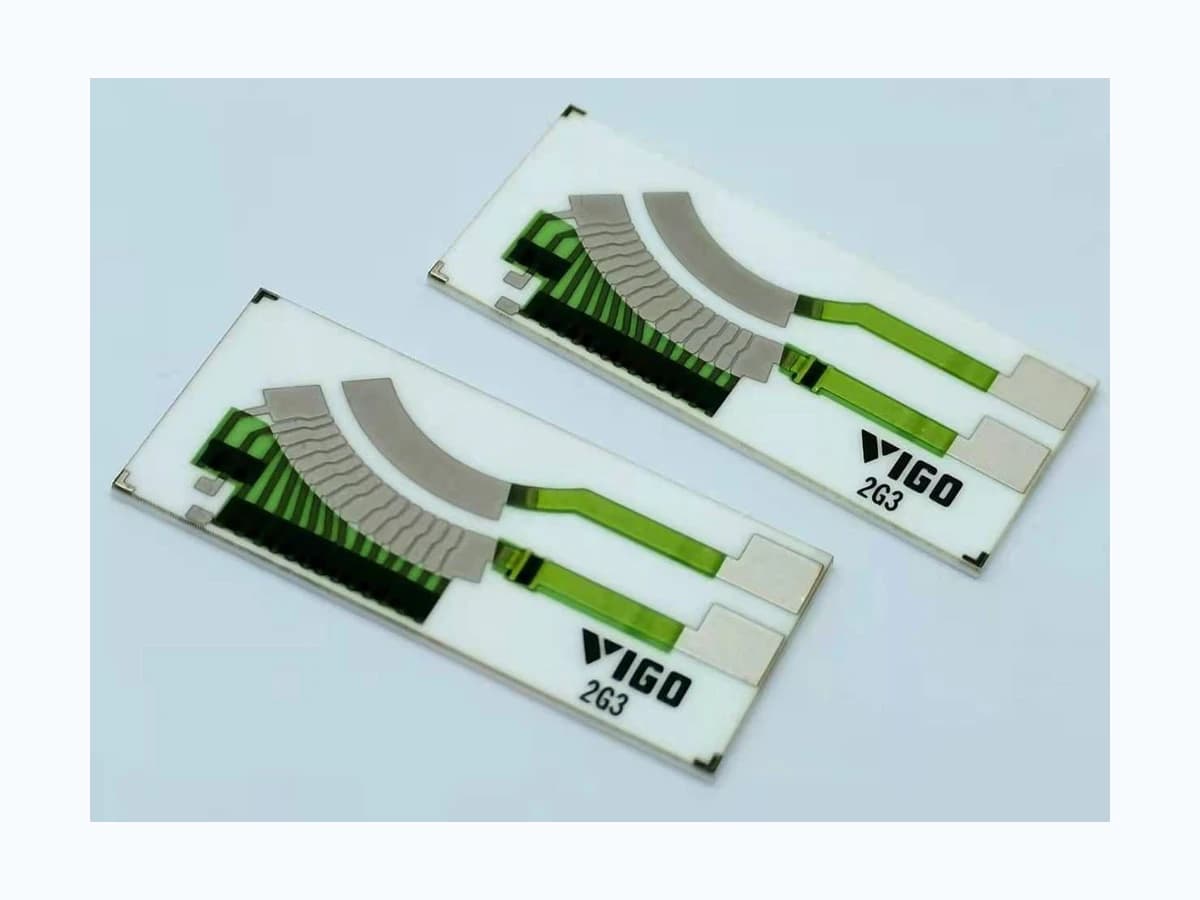
Overview
Oil and other vehicle-fluid level systems need a fluid-specific architecture before component selection. For a contact-based resistive route, this guide organizes reservoir geometry, density and temperature effects, float or linkage motion, contact behavior, sealing, electronics, diagnostics, and vehicle-level validation while keeping dielectric, ultrasonic, optical, and magnetically coupled alternatives as separate architectures and keeping the resistor card separate from the complete sensing assembly.
Failure controls
These are review prompts, not evidence that every risk applies or that every test is available.
- A
A design transferred from fuel service can fail because oil or another vehicle fluid has different density, viscosity, additives, temperature, and deposit behavior.
- B
Thermal expansion or vehicle attitude can change the relationship between fill quantity and local reservoir level.
- C
Deposits, sludge, aeration, or return flow can obstruct a float or make a stable liquid level unavailable at the sensing point.
- D
Mechanical hysteresis and contact hysteresis can combine, making a single-direction calibration misleading.
- E
An unverified seal or connector boundary can expose the resistive element or electronics to unintended fluid and contamination.
- F
Controller filtering may conceal intermittent contact during a bench sweep yet produce delayed or implausible indication in service.
- G
Results from dielectric, ultrasonic, optical, or magnetically coupled sensors cannot be used to qualify a contact-based resistive sender without a route-specific correlation.
Engineering review matrix
Each row links a design variable to evidence that can support a drawing or release decision.
| Variable | Control question | Verification route |
|---|---|---|
| Fluid identity and condition | What named fluid, formulation or additive range, contamination state, aeration, and aging condition define the exposure? | The OEM or designated validation owner should use controlled fluid samples and record identity, condition, temperature, duration, bias, and pre/post inspection rather than relying on a generic oil label. |
| Temperature and density | How do fluid density, viscosity, thermal expansion, and reservoir dimensions change over the required temperature states? | Measure indicated level and mechanism response at defined stabilized temperatures using the same reference-volume convention. |
| Reservoir geometry and attitude | Which datum, mounting angle, slopes, baffles, return streams, and vehicle attitudes alter the local level seen by the mechanism? | Correlate fill quantity and local level at the agreed attitudes, including the minimum-level region where geometry is most sensitive. |
| Float or actuator mechanics | What buoyancy, travel, pivot, stop, clearance, friction, deposit allowance, and tolerance stack convert fluid level into sensor motion? | Cycle the mechanism through forward and reverse travel while recording sticking, backlash, endpoint position, and repeatability. |
| Resistive track and contact | Which curve, track path, mating contact, normal load, speed, wear profile, and exposed-interface boundary apply? | For a contact-based resistive route, the system validation owner should measure the complete transfer curve, contact variation, discontinuity, and visual wear with the specified wiper. Apply a representative fluid condition only where the released assembly places that interface in the wetted or exposed boundary. |
| Sealing and assembly interface | Which seals, connectors, fasteners, barriers, vent paths, and assembly processes prevent leakage or unintended fluid access? | The OEM or designated assembly-validation owner should inspect and test the assembled boundary under pressure, temperature, vibration, and exposure states selected by the OEM risk assessment. |
| Electronics and diagnostics | What excitation, input impedance, filtering, plausibility range, fault thresholds, sampling, and response are applied by the controller? | Replay valid curves and injected open, short, intermittent, stuck, and out-of-range conditions at the controller interface. |
Fluid-specific sensing boundary
The order makes assumptions and ownership visible before a result is promoted to a requirement.
- 01
Name the fluid and operating envelope
Identify the actual fluid family, additives, contamination, temperature states, aeration, service interval, and whether the sensor is immersed, splashed, vapor-exposed, or isolated behind a barrier.
- 02
Define reservoir-level meaning
Tie the required indication points to reservoir geometry, vehicle attitude, thermal expansion, pump or return flow, minimum safe level, and the datum used during assembly and service.
- 03
Resolve the mechanical conversion
Select the sensing and coupling architecture first. A direct float, lever, shaft, and wiper route must be evaluated as a contact-based resistive chain; magnetically coupled, dielectric, ultrasonic, and optical routes require their own signal and validation chains. For the selected route, account for buoyancy changes, viscosity, clearances, stops, backlash, deposits, and tolerance accumulation.
- 04
Specify output and fault regions
Release the electrical curve, reference conditions, controller load, filtering, valid range, empty and full behavior, and diagnostic treatment of opens, shorts, sticking, and intermittent contact.
- 05
Validate the installed assembly
Correlate known fluid levels with raw and interpreted output across relevant temperature, attitude, motion, and exposure states, retaining the assembly revision and measurement uncertainty.
Reference boundary
Public method sources
These sources support the engineering method and terminology used in this technical guide. They do not establish a ThickFilmPCB material list, capability limit, customer result, certification, or finished-product specification.
- 01SAE 970847 — Oil-Quality Prediction and Oil-Level Detection
Describes a QLT architecture that measures fluid dielectric number, level, and temperature and discusses aging, temperature compensation, and mechanical and electrical interfaces. It is system-context evidence, not support for a contact-based resistive or wiper design.
- 02SAE 2008-01-0906 — Combi-Sensor for Oil Level and Oil Quality Management
Describes an ultrasonic oil-level element combined with a tuning-fork oil-condition element and a digital ECU interface. It supports separating sensing, conditioning, and interpretation, but not a resistive track or wiper route.
- 03SAE 973242 — Optical Fluid-Level Sensor for Automotive Environments
Describes an optical automotive coolant-level sensor and its housing in a high-temperature, pressurized environment. It is an architecture and housing-boundary example, not evidence for oil service or a resistive sender.
Inputs for a practical review
Unknown values may be labelled unknown. The review should convert uncertainty into an explicit decision or validation task.
Send Drawings- 01
Reservoir drawing, installation orientation, level datum, usable volume, baffles, flow paths, and mounting interface
- 02
Exact fluid identity or controlled fluid family, additives, contamination, temperature, pressure, aeration, and service profile
- 03
Float, linkage, shaft, magnet, wiper, stops, clearances, seals, and connector details
- 04
Required level-to-resistance, ratio, or voltage table with reference conditions, tolerances, and empty/full behavior
- 05
Excitation, controller input circuit, sampling, filtering, plausibility limits, fault thresholds, and recovery rules
- 06
Required environmental, mechanical, fluid-exposure, sealing, electrical, and assembly-level validation conditions
- 07
Prototype quantity, annual demand estimate, drawing revision, acceptance ownership, and reporting needs