
On this page
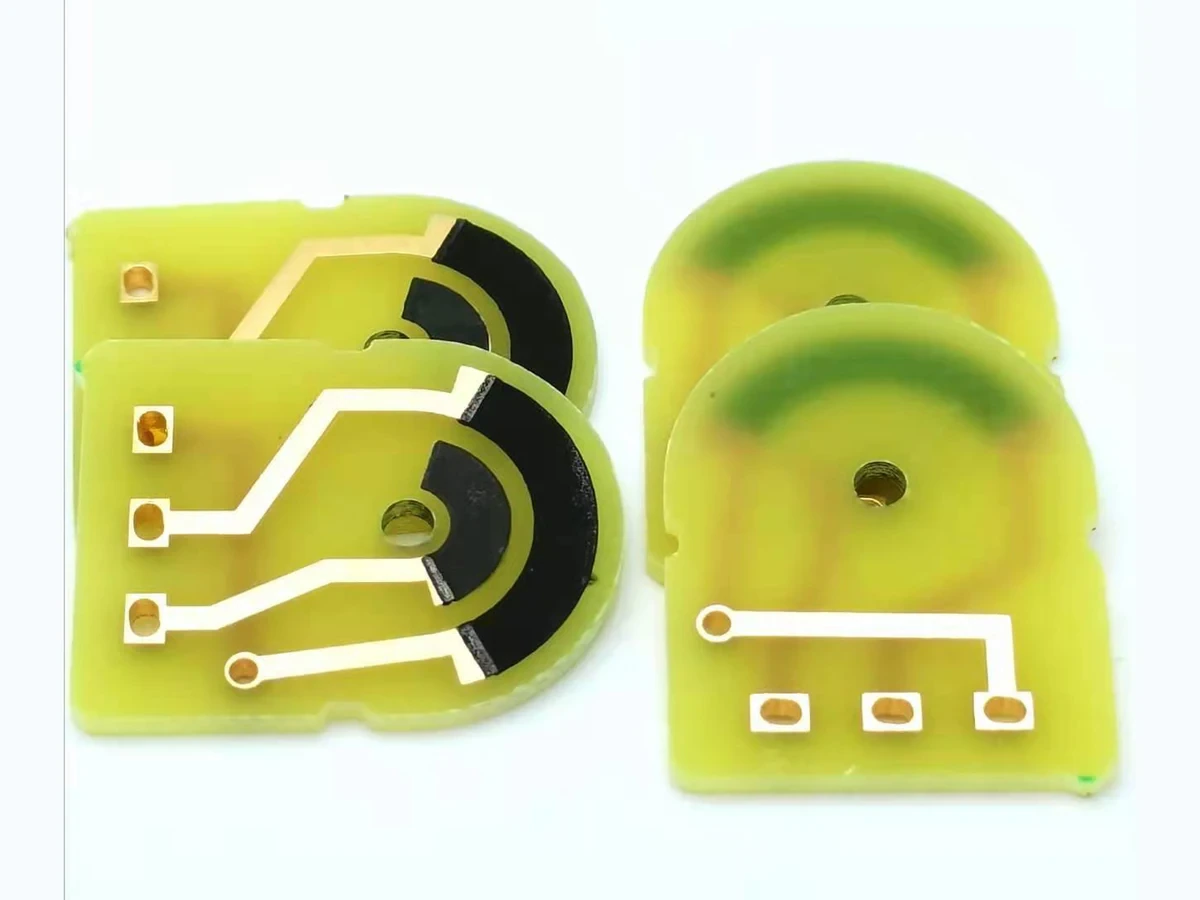
A valve feedback signal reports the position of the mechanism that drives its sensor. If that point is separated from the valve member by backlash, compliance or a slipping connection, a precise resistor track can still report an incomplete picture of valve motion. Diagnosis starts by naming the position being measured and comparing command, actual valve position and sensor output in both directions. The resulting data separates track behavior from the mechanical path around it.
Key design decisions
- Identify whether the track follows the motor, actuator shaft, valve stem or final closure member.
- Measure forward and reverse output against an independent position reference, not only against the command.
- Evaluate local output slope, noise and acquisition resolution together before assigning position resolution.
Locate the feedback point in the drivetrain
Draw the path from actuator drive through gears, couplings and shaft connections to the valve member. Mark where the resistor-card wiper is attached. Any motion or lost motion downstream of that point can escape direct observation by the track. A motor-mounted sensor and a stem-mounted sensor therefore answer different position questions.
Friction, backlash and shaft wind-up can create deadband between the drive and the controlled valve member. For a resistive feedback design, preserve those mechanical contributors as separate parts of the system model. A sensor curve can be evaluated independently, but the installed feedback performance must include the coupling between its measurement point and the actual controlled member.
Separate backlash, hysteresis and electrical irregularity
Backlash is lost motion associated with clearance when direction changes. Hysteresis is a direction- or history-dependent difference at the same referenced input or position. Electrical irregularity can include contact noise or a local curve deviation. These effects can overlap in a recorded signal, but their diagnostic comparisons differ.
Do not call every difference between opening and closing traces track hysteresis. If the horizontal coordinate is command rather than measured valve position, the difference may come from the drivetrain. Replot sensor output against an independent position measurement. A loop that disappears in that plot points toward command-to-motion behavior; a remaining difference requires closer examination of the sensor coupling and contact.
Use full sweeps and small reversals
Begin with a controlled opening sweep across the intended travel, followed by a closing sweep at a comparable speed and load. Record command, reference position and sensor output on the same time base. Include sufficient dwell where static readings are required, and distinguish those readings from dynamic samples.
Then perform small reversals at selected positions. Backlash may appear as motion of an upstream drive without immediate motion of the downstream reference. Repeat at several valve loads or operating conditions where these are part of the intended review. A no-load bench mechanism can behave differently from the installed valve, so keep the load condition attached to each conclusion.
Convert the output difference into local position units
For a locally smooth curve, divide a small output difference by the local output slope to estimate equivalent position error. A one-ohm difference means different position errors in steep and shallow regions. Use the slope at the point being evaluated, with units stated explicitly.
Assume a hypothetical track slope of two ohms per degree and a forward-reverse difference of 0.6 ohm at the same independently measured angle. The equivalent difference is 0.3 degree. If the local slope falls to 0.5 ohm per degree elsewhere, the same electrical difference corresponds to 1.2 degrees. This illustrates why total-span resolution can conceal a weak local region.
Δxequiv ≈ Δy / (dy/dx)
- x is actual valve or sensor travel in the named coordinate.
- y is measured resistance or voltage output.
- dy/dx is the local output slope and must be nonzero for this conversion.
The output difference is small and the local curve is sufficiently smooth; a dead zone or discontinuity cannot be represented by this approximation.
Use the three recorded signals to distinguish causes
The command, independent reference and resistor output form a useful diagnostic set. Compare their relationships before changing the card. The same apparent feedback delay can result from mechanical motion, acquisition timing or signal filtering.
| Observed relationship | Contributor to examine | Discriminating check |
|---|---|---|
| Drive command reverses before valve reference moves | Backlash, friction or mechanical compliance | Observe upstream and downstream motion during small reversals |
| Valve reference moves but resistor output does not | Sensor coupling, contact path or electrical dead region | Inspect the wiper motion and raw output at that position |
| Raw output follows motion but filtered output lags | Acquisition or filtering delay | Compare raw and processed signals with synchronized timestamps |
| Forward-reverse error remains versus actual position | Sensor coupling hysteresis or directional contact behavior | Repeat with the card on a controlled independent fixture |
| Error grows under load while bench curve is stable | Drivetrain compliance or load-dependent alignment | Compare the same position sequence under defined loads |
| Random spikes occur at fixed travel locations | Local track or wiper-contact condition | Inspect contact path and repeat at several speeds |
Distinguish digital increments from usable feedback resolution
An analog-to-digital converter's step size is only one contributor to position resolution. The sensor's local slope converts voltage noise into position uncertainty, while mechanical play can prevent small commanded changes from reaching the valve. Increasing converter resolution cannot remove those effects.
Estimate the electrical position increment from converter step divided by local slope, then compare it with measured noise and repeated-position scatter. If noise spans several codes, quoting one code as achieved resolution is misleading. Use repeated small movements with an independent position reference to establish what changes the complete feedback system can distinguish under the stated conditions.
Protect the track from unintended coupling loads
The wiper support should transmit the intended motion without imposing uncontrolled lateral force, tilt or substrate bending. Shaft misalignment and mounting distortion can change contact position and force through travel. Inspect the installed path, particularly near end stops where the mechanism may apply additional load.
Keep mechanical stops separate from a track feature unless the design specifically assigns that function. The active electrical region should correspond to the intended usable motion with defined behavior at both ends. If the mechanism overruns the calibrated region, state the output behavior and review the physical contact path rather than extrapolating the center-region curve.
Specify feedback at the position that matters to control
Define the measured mechanical member, travel range, direction, local error limits and relevant operating loads. Include forward-reverse behavior and dynamic timing where the controller relies on them. State whether the card is accepted independently or as part of the actuator assembly, because the measured boundaries differ.
For quotation, provide the drivetrain sketch and synchronized traces together with the target curve. This allows card geometry and contact behavior to be reviewed without assigning drivetrain errors to the printed track. The final control performance remains a property of the valve, actuator, sensor interface and controller evaluated together under the intended operating conditions.
Send the valve feedback motion chain
Include the sensor's attachment point and synchronized motion data so electrical and mechanical effects can be separated.
- Drivetrain sketch identifying command, sensor coupling and actual valve-member position.
- Target output curve and local position-error requirements.
- Forward, reverse and small-reversal traces with independent position reference.
- Actuator load, speed, mounting and end-stop conditions.
- Receiver resolution, sample timing, raw output and filtering definition.
The drawing-upload form loads as you reach this section.